Sitemap
A list of all the posts and pages found on the site. For you robots out there, there is an XML version available for digesting as well.
Pages
Posts
Future Blog Post
Published:
This post will show up by default. To disable scheduling of future posts, edit config.yml and set future: false.
Blog Post number 4
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool.
Headings are cool
You can have many headings
Aren’t headings cool?
Blog Post number 3
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool.
Headings are cool
You can have many headings
Aren’t headings cool?
Blog Post number 2
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool.
Headings are cool
You can have many headings
Aren’t headings cool?
Blog Post number 1
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool.
Headings are cool
You can have many headings
Aren’t headings cool?
publications
Implementation of an Ethernet Bridge Using Avalon Memory-Mapped Interface
Published in Emerging Research in Electronics, Computer Science and Technology: Proceedings of International Conference, ICERECT 2012, 2013
Implementation of an Ethernet bridge using the Avalon memory-mapped interface.
Recommended citation: Bharadwaj, A. S. & Mankkadan, D. (2013). "Implementation of an Ethernet Bridge Using Avalon Memory-Mapped Interface." Emerging Research in Electronics, Computer Science and Technology: Proceedings of International Conference, ICERECT 2012. Springer India, New Delhi. pp. 407-412.
Detection of Microcalcification with Top-Hat Transform and the Gibbs Random Fields
Published in 37th Annual International Conference of the IEEE Engineering in Medicine and Biology Society (EMBC), 2015
A novel CAD method combining fuzzy C-means clustering, top-hat transform, watershed segmentation, and Gibbs random fields to detect microcalcifications in digital mammograms, achieving a 94.4% detection rate.
Recommended citation: Bharadwaj, A. S. & Celenk, M. (2015). "Detection of Microcalcification with Top-Hat Transform and the Gibbs Random Fields." 37th Annual International Conference of the IEEE Engineering in Medicine and Biology Society (EMBC). Milan, Italy. p. 6382.
Download Paper
A Real-time Relative Navigation Capability for Multi-copter Collision Avoidance
Published in Proceedings of the 2016 International Technical Meeting of The Institute of Navigation, 2016
Multi-copter platforms equipped with GNSS, inertial sensors, and communication links implementing relative navigation and collision avoidance algorithms on embedded ROS processors.
Recommended citation: Kastelein, M., Gilabert, R., Schultz, A., Bharadwaj, A., Shiflett, K., & Uijt de Haag, M. (2016). "A Real-time Relative Navigation Capability for Multi-copter Collision Avoidance." Proceedings of the 2016 International Technical Meeting of The Institute of Navigation. pp. 657-663.
Download Paper
A Navigation and Mapping Method for UAS during Under-the-Canopy Forest Operations
Published in 2016 IEEE/ION Position, Location and Navigation Symposium (PLANS), 2016
A simultaneous navigation and mapping (SNAM) method for multi-copter UAS operating in GNSS-degraded forest environments, using tightly-coupled GNSS/IMU and multi-scanner ICP-based mapping.
Recommended citation: Schultz, A., Gilabert, R., Bharadwaj, A., Uijt de Haag, M., & Zhu, Z. (2016). "A Navigation and Mapping Method for UAS during Under-the-Canopy Forest Operations." 2016 IEEE/ION Position, Location and Navigation Symposium (PLANS). Savannah, GA. pp. 739-746. doi:10.1109/PLANS.2016.7479768
Download Paper
Small-UAS Navigation using 3D Imager and Infrared Camera in Structured Environments
Published in 2016 IEEE/ION Position, Location and Navigation Symposium (PLANS), 2016
A GNSS-denied navigation and thermal mapping method integrating depth imagery from a 3D TOF imager and LWIR camera with an IMU for autonomous small-UAS operation in maintenance tunnels.
Recommended citation: Bharadwaj, A., Schultz, A., Gilabert, R., Huff, J., & Uijt de Haag, M. (2016). "Small-UAS Navigation using 3D Imager and Infrared Camera in Structured Environments." 2016 IEEE/ION Position, Location and Navigation Symposium (PLANS). Savannah, GA. pp. 599-606. doi:10.1109/PLANS.2016.7479751
Download Paper
Keynote: Navigating Small-UAS in Tunnels for Maintenance and Surveillance Operations
Published in Proceedings of the ION 2017 Pacific PNT Meeting, 2017
Keynote paper on autonomous small-UAS navigation in tunnel environments for maintenance and surveillance operations.
Recommended citation: Bharadwaj, A. S. & Uijt de Haag, M. (2017). "Keynote: Navigating Small-UAS in Tunnels for Maintenance and Surveillance Operations." Proceedings of the ION 2017 Pacific PNT Meeting. pp. 1065-1076.
Methods and Apparatuses for Detection of Abnormalities in Low-Contrast Images
Published in US Patent Application Publication (US20180053297A1), Ohio University, 2018
US Patent Application (US20180053297A1) for a computer-implemented method detecting abnormalities in low-contrast medical images using image segmentation, Gibbs random field clique analysis, and network-based delivery.
Recommended citation: Celenk, M. & Bharadwaj, A. S. (2018). "Methods and Apparatuses for Detection of Abnormalities in Low-Contrast Images." US Patent Application Publication No. US 2018/0053297 A1. Filed Aug. 11, 2017.
Download Paper
A Perception Payload for Small-UAS Navigation in Structured Environments
Published in Ohio University, 2018
M.S. thesis on the design of a perception payload enabling small-UAS navigation in GNSS-denied structured environments.
Recommended citation: Bharadwaj, A. S. (2018). "A Perception Payload for Small-UAS Navigation in Structured Environments." M.S. Thesis, Ohio University.
Download Paper
APC2Mesh: Bridging the gap from occluded building façades to full 3D models
Published in ISPRS Journal of Photogrammetry and Remote Sensing, 2024
A method integrating point completion into a 3D mesh reconstruction pipeline to generate high-fidelity digital twin models of urban buildings from occluded airborne LiDAR point clouds.
Recommended citation: Akwensi, P. H., Bharadwaj, A., & Wang, R. (2024). "APC2Mesh: Bridging the gap from occluded building façades to full 3D models." ISPRS Journal of Photogrammetry and Remote Sensing.
Download Paper
Points2Model: A Neural-Guided 3D Building Wireframe Reconstruction from Airborne LiDAR Point Clouds
Published in International Journal of Digital Earth, 2025
A neural-guided pipeline for reconstructing 3D building wireframe models from airborne LiDAR point clouds, addressing façade/roof occlusions, point density variations, and noise.
Recommended citation: Akwensi, P. H., Bharadwaj, A., & Wang, R. (2025). "Points2Model: A Neural-Guided 3D Building Wireframe Reconstruction from Airborne LiDAR Point Clouds." International Journal of Digital Earth. 18(1), 2458682.
Download Paper
Cost-Effective Mapping Platform to Generate HD-Maps for Autonomous Vehicles and Digital Twins
Published in University of Calgary, Schulich School of Engineering, 2026
Ph.D. dissertation on a cost-effective mobile mapping system for HD-map generation, covering photogrammetric camera calibration, learning-based LiDAR–camera calibration, and neural implicit LiDAR–inertial odometry.
Recommended citation: Bharadwaj, A. S. (2026). "Cost-Effective Mapping Platform to Generate HD-Maps for Autonomous Vehicles and Digital Twins." Ph.D. Dissertation, University of Calgary. doi:10.11575/PRISM/51522
Download Paper
Beyond Checkerboards: Advantages of Photogrammetric Camera Calibration for Robust 3D Vision and Novel-View Generation
Published in Remote Sensing, 2026
Revisits intrinsic camera calibration through photogrammetric self-calibration (PSC), showing it consistently outperforms checkerboard calibration for SfM, visual SLAM, and novel-view synthesis.
Recommended citation: Bharadwaj, A. & Lichti, D. D. (2026). "Beyond Checkerboards: Advantages of Photogrammetric Camera Calibration for Robust 3D Vision and Novel-View Generation." Remote Sensing. 18(13), 2220.
Download Paper
research
UAS Navigation in Challenging Environments
Research Assistant at Ohio University: Autonomous UAS navigation and mapping for forest, urban, and indoor environments using SLAM, sensor fusion, and custom hardware.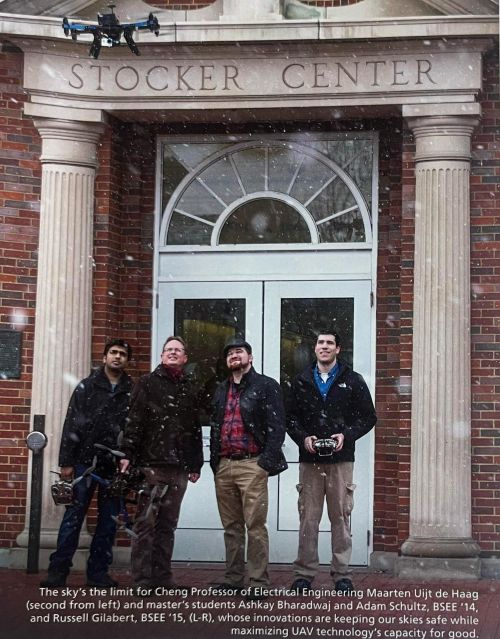
A Perception Payload for Small-UAS Navigation in Structured Environments
Master’s Thesis (Ohio University, 2018): Multi-sensor perception payload integrating 3D depth and thermal imaging with IMU for autonomous UAS navigation in GNSS-denied maintenance tunnels.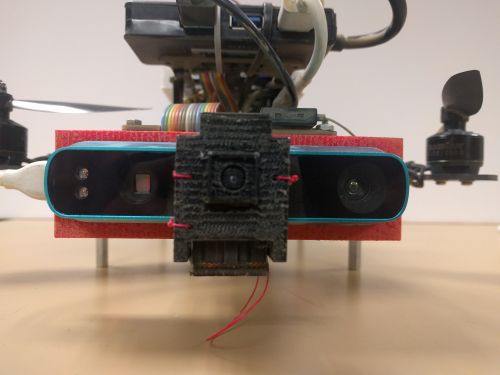
3D Building Reconstruction from Airborne LiDAR
PhD Research (University of Calgary): Neural-guided 3D building reconstruction and digital twin generation from occluded airborne LiDAR point clouds using deep learning.
Detection of Abnormalities in Medical Images
Early breast cancer detection: A multi-stage CAD pipeline using top-hat transform, Gibbs random fields, and fuzzy clustering to detect microcalcifications in mammograms (94.4% detection rate). US Patent filed.
talks
Talk 1 on Relevant Topic in Your Field
Published:
This is a description of your talk, which is a markdown file that can be all markdown-ified like any other post. Yay markdown!
Tutorial 1 on Relevant Topic in Your Field
Published:
This is a description of your tutorial, note the different field in type. This is a markdown files that can be all markdown-ified like any other post. Yay markdown!
Talk 2 on Relevant Topic in Your Field
Published:
This is a description of your talk, which is a markdown files that can be all markdown-ified like any other post. Yay markdown!
Conference Proceeding talk 3 on Relevant Topic in Your Field
Published:
This is a description of your conference proceedings talk, note the different field in type. You can put anything in this field.
teaching
ET 2100 & CS 2400: C/C++ Programming
Teaching Assistant, Ohio University, 2014
Term: August 2014 – May 2016
EE 5673: Embedded Systems
Teaching Assistant, Ohio University, 2016
Term: August 2016 – December 2016
EE 5143: Design of Digital Circuits
Teaching Assistant, Ohio University, 2017
Term: January 2017 – May 2017
DATA 201: Thinking with Data
Teaching Assistant, University of Calgary, 2021
Term: Fall 2021
ENDG 233: Programming with Data
Teaching Assistant (Active Learning), University of Calgary, 2022
Terms: Fall 2021, Fall 2022
ENDG 407: Computational Numerical Methods
Co-Instructor, University of Calgary, 2023
Terms: Winter 2022, Winter 2023
ENGO 559: Digital Imaging and Applications
Co-Instructor, University of Calgary, 2023
Term: Winter 2023